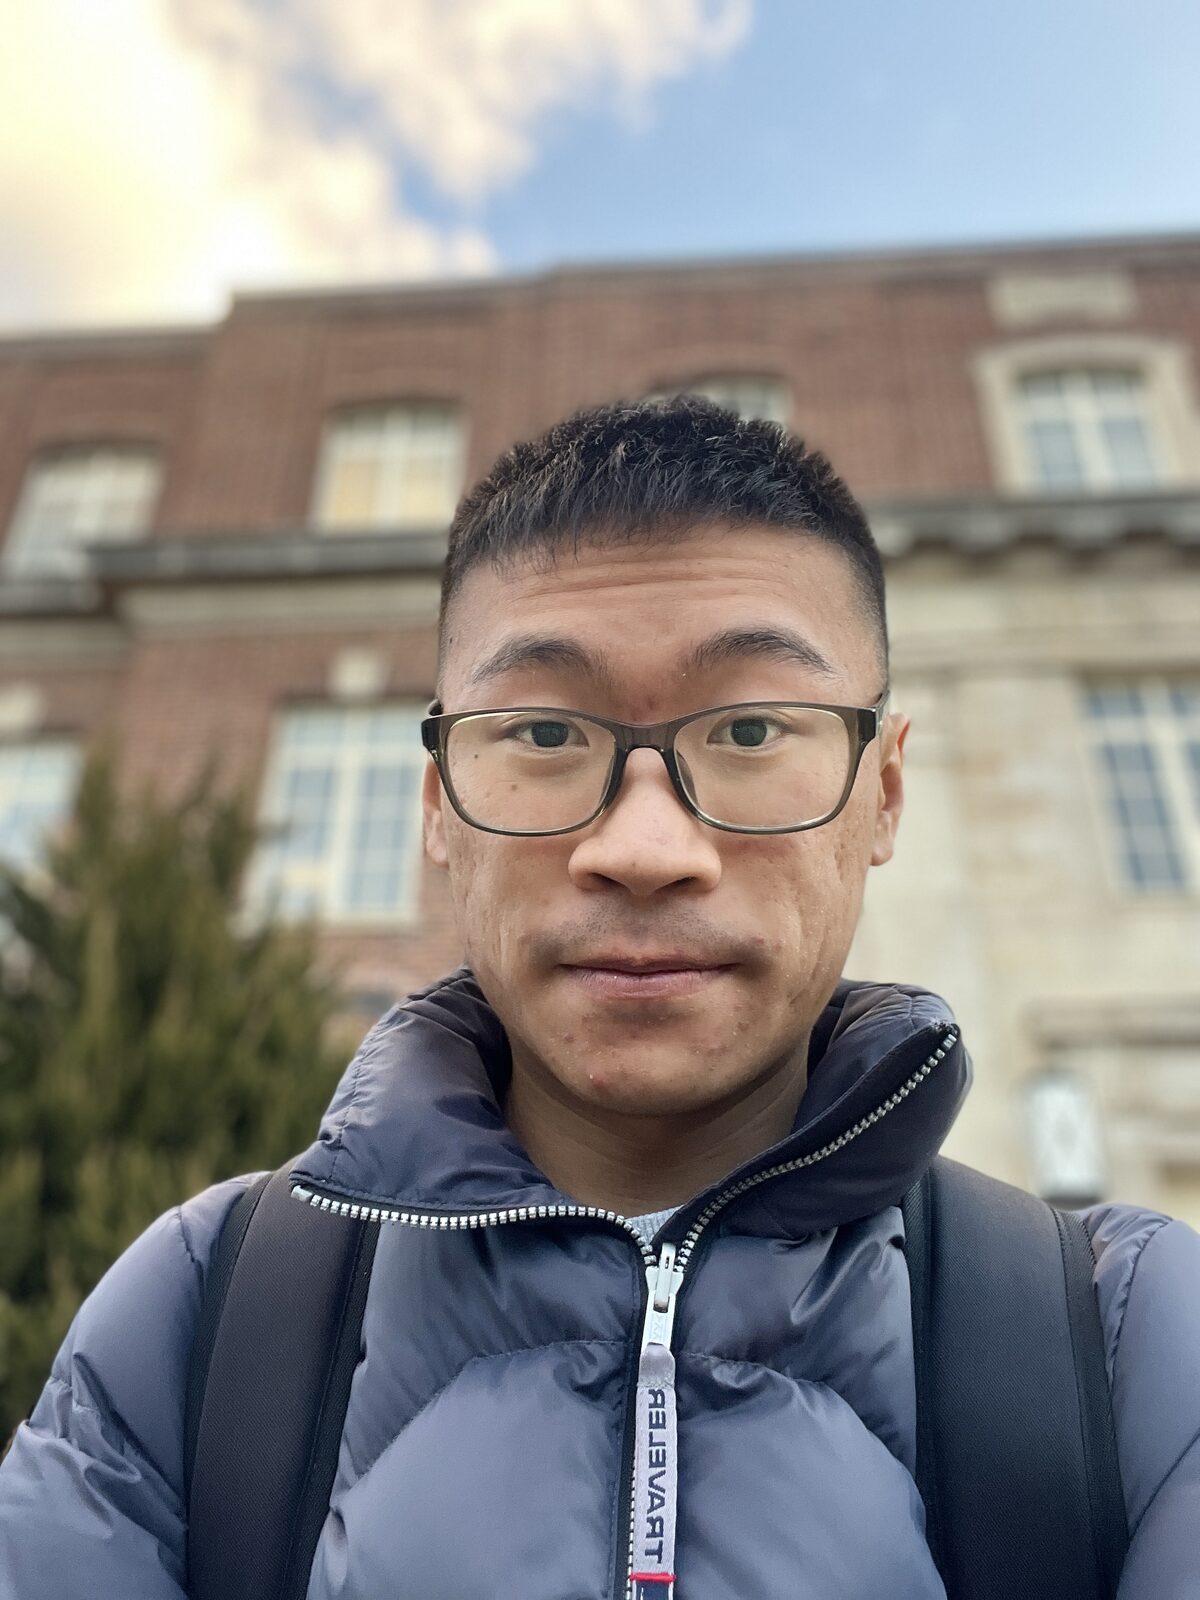
Hung-Chieh Wu
Ph.D. Candidate in Electrical Engineering · Penn State
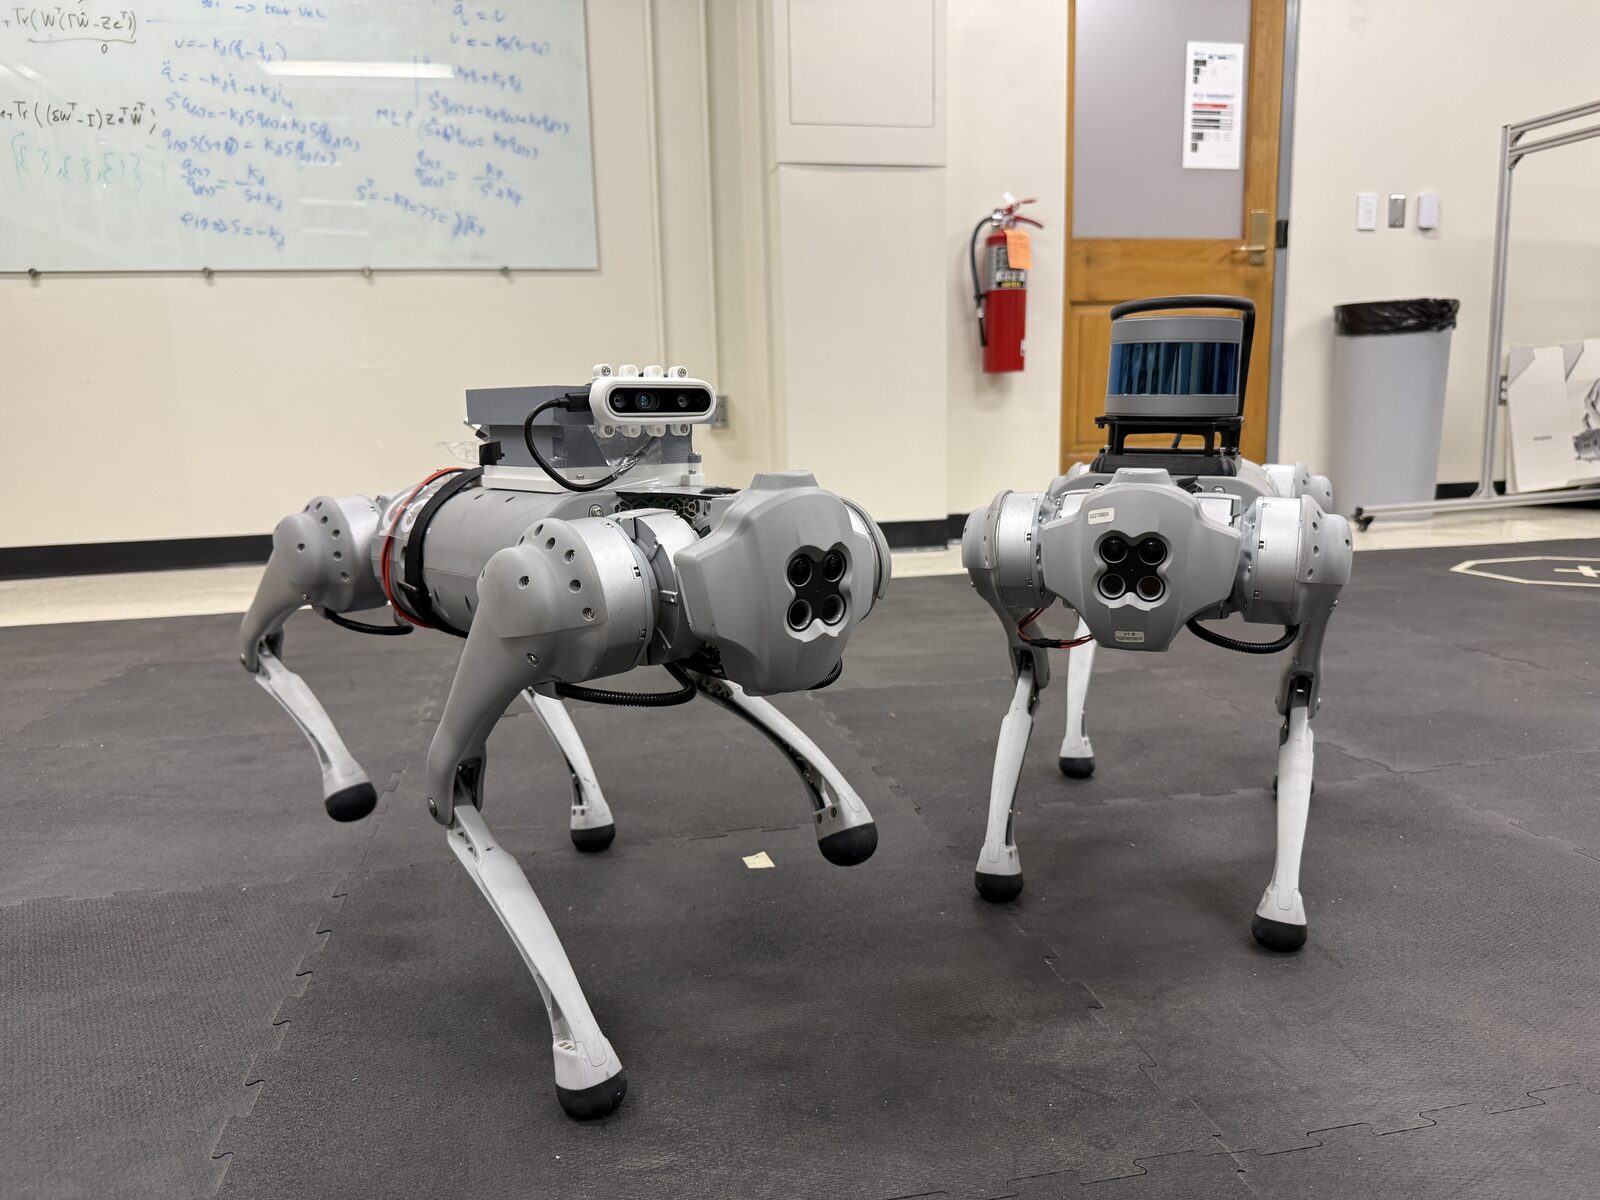
I work on learning-based control and estimation for robotics — quadruped locomotion, navigation, state estimation, and now exploring world-model navigation. I currently work with Professor Donald Ebeigbe in the Control & Autonomous Robotics Lab at Penn State. My goal is to make legged robots move and navigate robustly in the real world by combining state-of-the-art learning-based methods such as reinforcement learning and world models.
News
- 2026 · Jun 16 StratMamba paper accepted at IEEE/RSJ IROS 2026.
- 2026 · Summer Joining AlphaZ Robotics for a summer internship again!
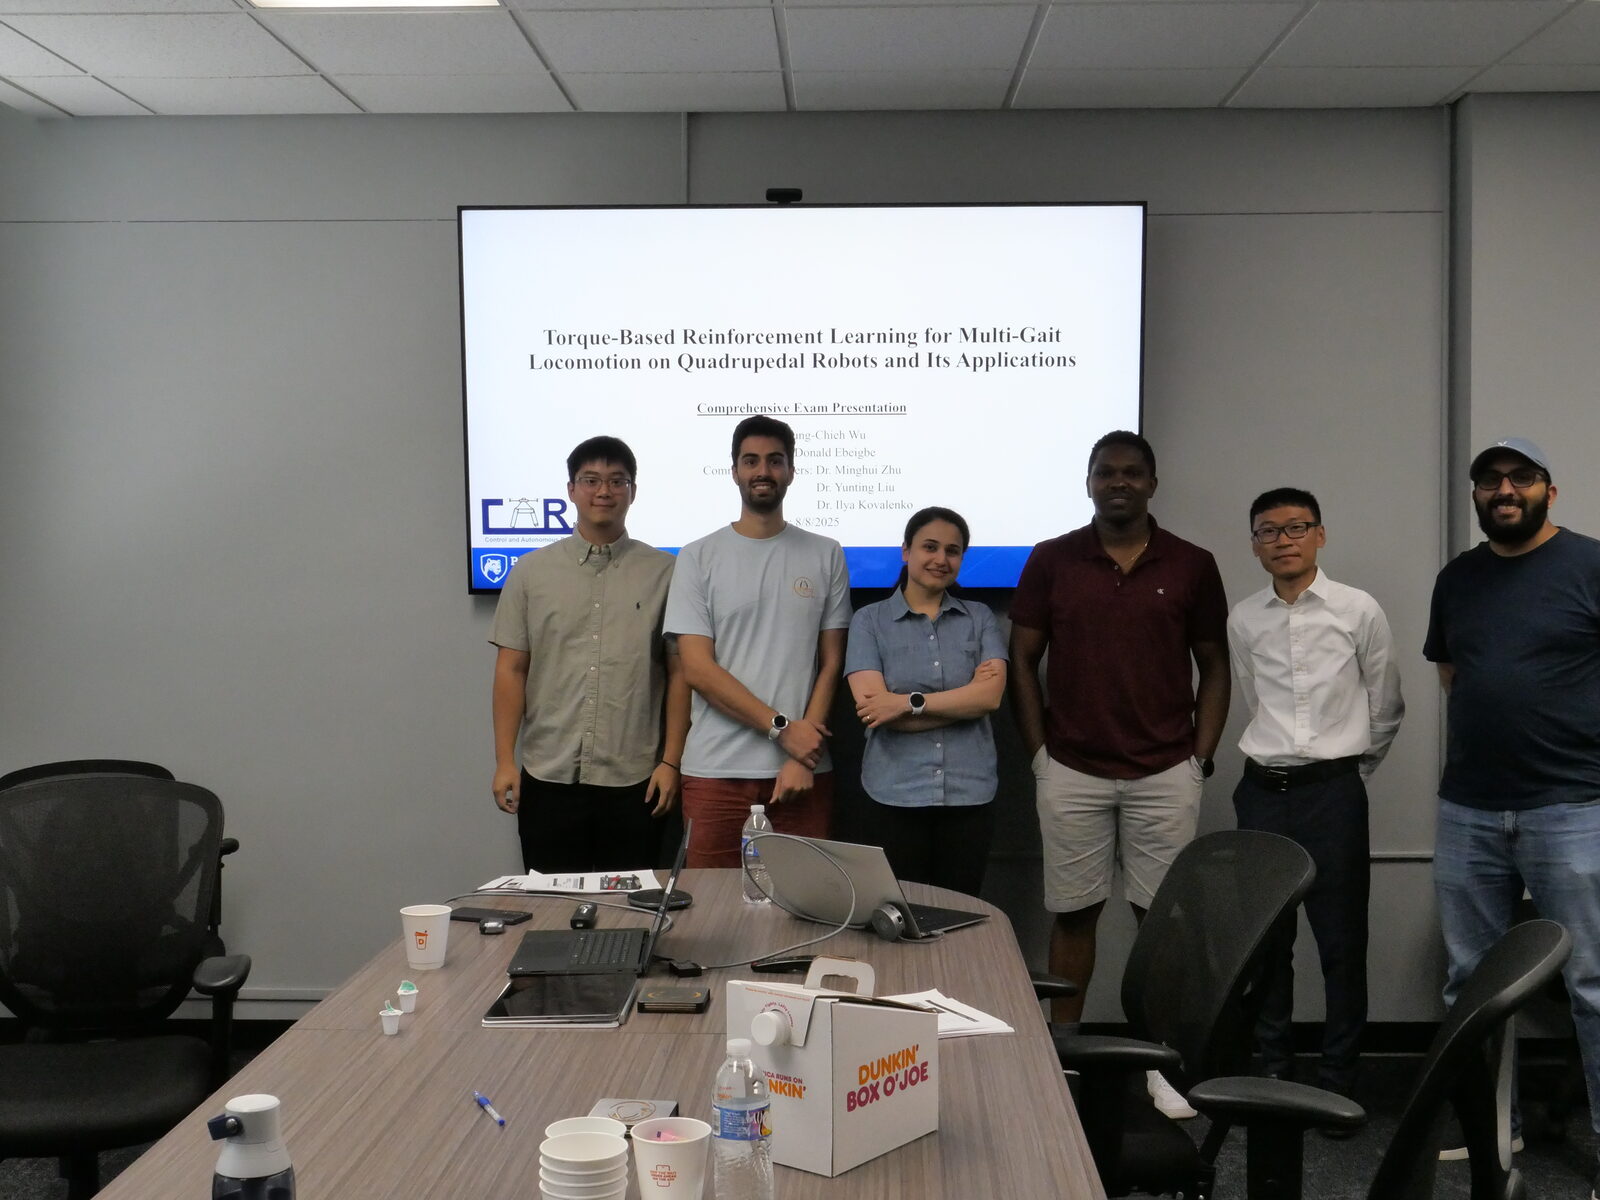
- 2025 · Aug 8 Passed the Comprehensive Exam and became a Penn State Ph.D. Candidate.
Research Interests
- Legged locomotion — torque-based reinforcement learning with adversarial imitation (AMP) for energy-efficient, robust quadruped gaits.
- Robot navigation — temporal, Mamba-based policies and learned local planners for long-horizon, LiDAR-based navigation in cluttered environments.
- State estimation — a Kalman-filter-inspired prediction–correction network for more accurate and reliable robot state estimation.
Education
Download CV- Ph.D. Candidate, Electrical Engineering — The Pennsylvania State University (Fall 2022 – Present, expected May 2027). Advisor: Prof. Donald Ebeigbe.
- B.S. in Bio-Industrial Mechatronics Engineering — National Chung Hsing University, Taiwan (Fall 2017 – Spring 2021). Advisor: Prof. Yao-Chuan Tsai.
Selected Experience
- Research Intern, AlphaZ Robotics (Summer 2025 – Present) — Mamba-based temporal policy for robot navigation, contributing to an accepted IROS 2026 paper.
- Research Assistant, Control & Autonomous Robotics Lab, PSU (Fall 2025 – Present) — Torque-based RL for energy-efficient quadruped locomotion and adversarial imitation learning for sim-to-real transfer.
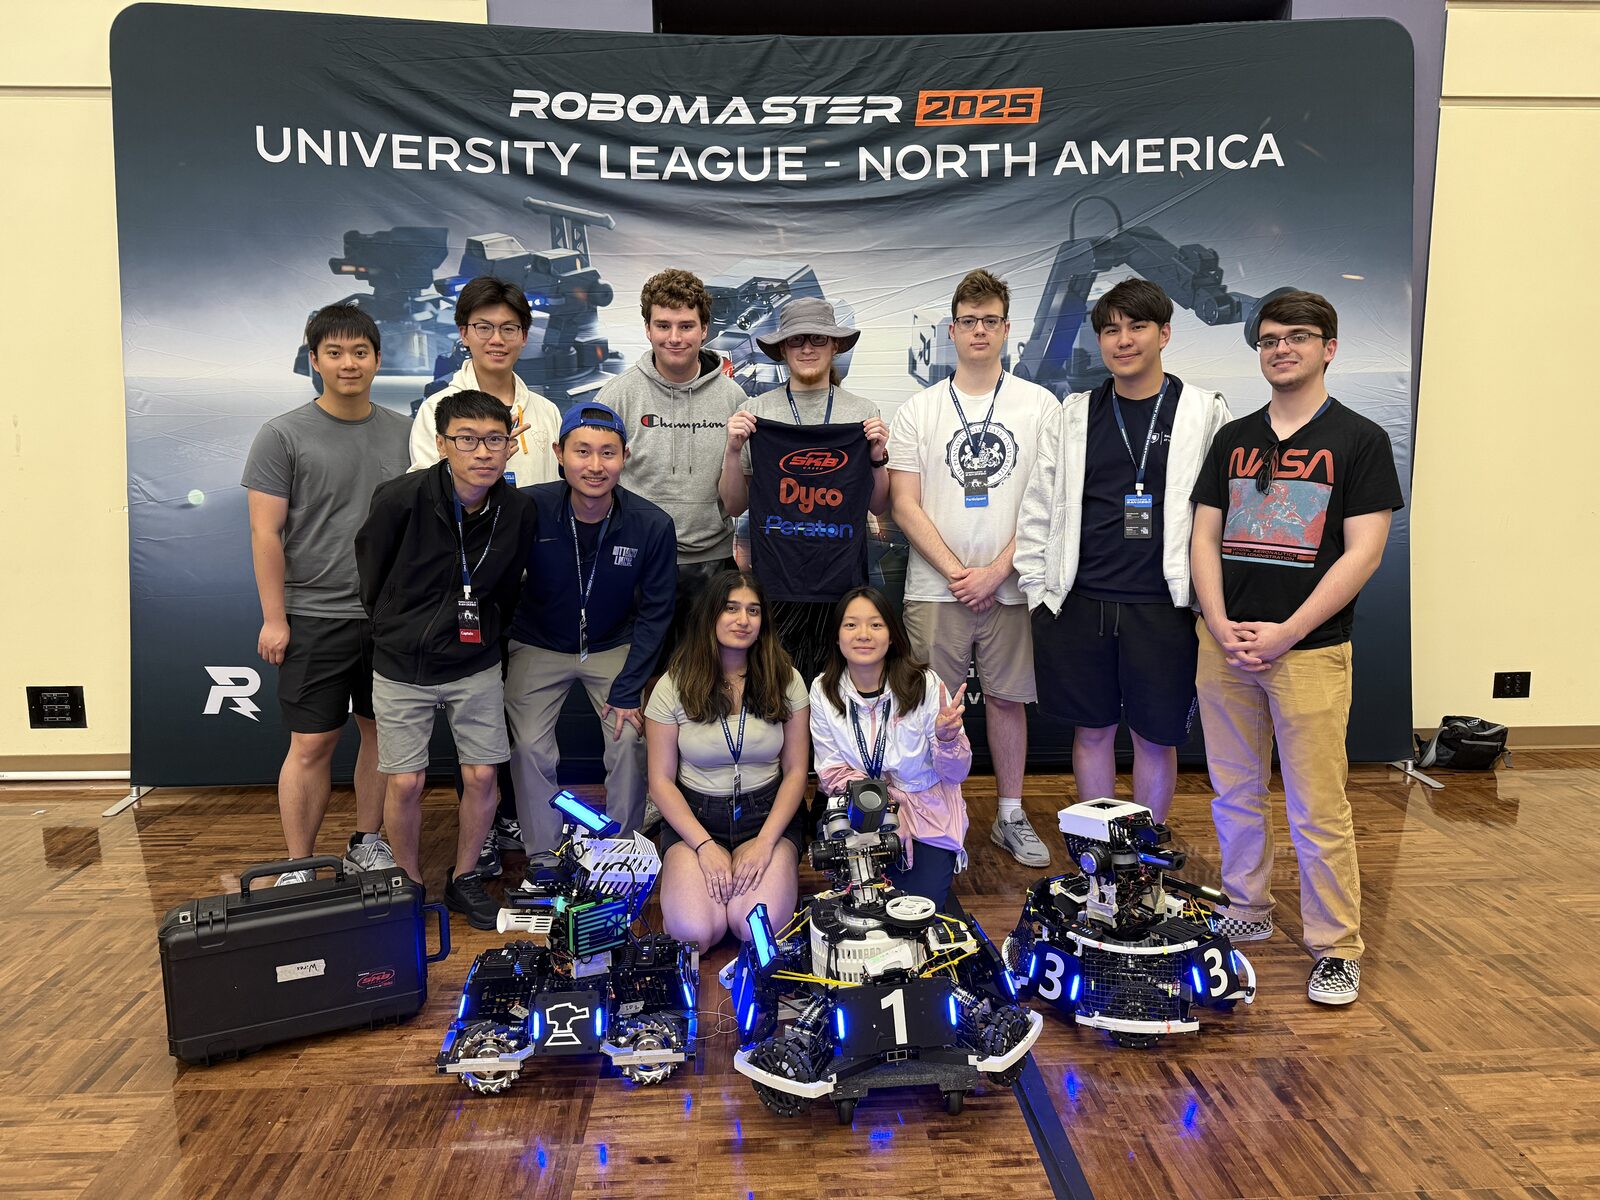
- Team Captain, Embedded Systems (RoboMaster), PSU Mechnittany (Fall 2024 – Summer 2025) — Led the embedded team to a Top-5 finish at the 2025 international competition.
- Teaching Assistant, Linear Control Systems, PSU (Fall 2023 – Spring 2025) — Led MATLAB/Simulink labs on state-space modeling, feedback control, and stability analysis.
Selected Publications
- H.-C. Wu and the AlphaZ Robotics Team, “StratMamba: Strategic and Reactive Stream Partitioning for Path-Efficient LiDAR-Based Obstacle Avoidance,” IEEE/RSJ IROS, 2026 (Accepted).
- K. Sinaei, H.-C. Wu, and D. Ebeigbe, “Safety-Critical Position Control of Robots: A Model-Free Approach,” American Control Conference (ACC), 2025.
Awards & Honors
- Melvin P. Bloom Memorial Graduate Fellowship in Electrical Engineering, Penn State (2024)
- NCHU Golden Key Award — top-performing student in the class (2021)
- Third Place, Undergraduate Research Poster Competition, BIME Department (2021)